Happy Mid-Autumn from all of us at Volumet. 中秋节快乐. The festival fell on Friday 25 September this year, the fifteenth day of the eighth lunar month, and we hope you had a clear sky and a good mooncake.
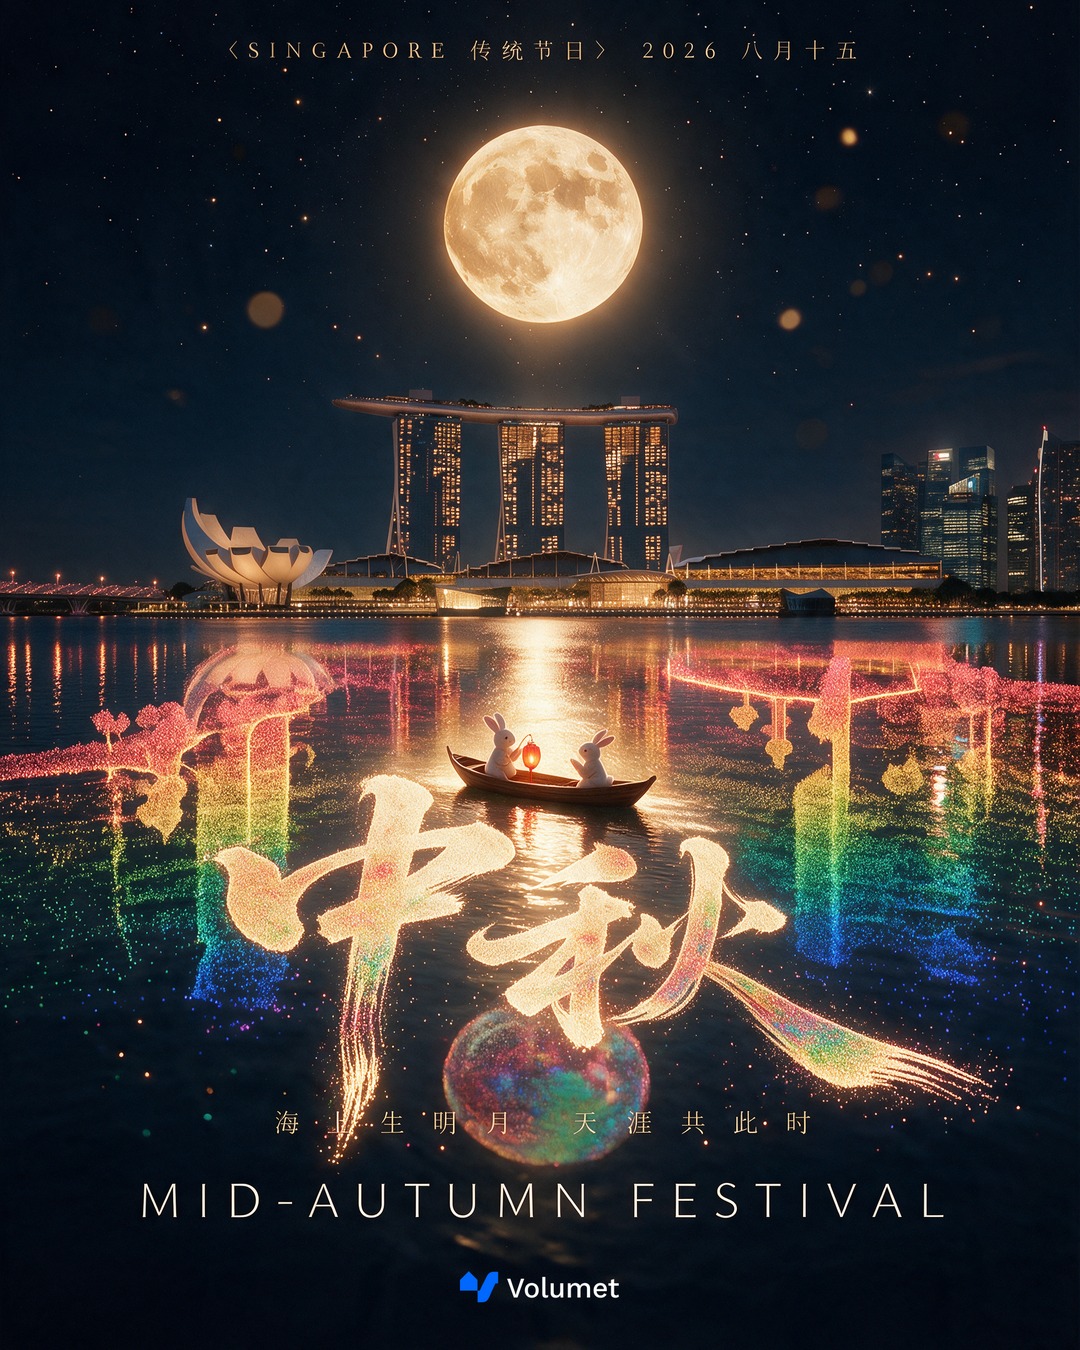
This year's poster puts Marina Bay above the waterline, drawn the way it looks to the eye, and the reflection below it drawn the way it would look in a colourised point cloud: millions of measured points, coloured by height. It is an illustration made for the festival, not a scan of the bay. But the idea behind it is real, and it is one of the first things we plan around on any waterfront or glass-heavy site.
Why a scan can see the same building twice
A LiDAR scanner measures distance by timing a laser pulse out to a surface and back. It assumes the pulse travelled in a straight line, so it places the point at that distance along the direction it fired.
Calm water, glass and polished stone break that assumption. They behave like mirrors to the laser. A pulse hits the surface, bounces off at an angle, strikes a building or a ceiling, and returns along the same path. The scanner has no way to know the pulse took a detour, so it records the extra distance as if the object sat behind the mirror.
The result is a set of ghost points: a mirrored copy of the skyline hanging below the surface of the bay, or a second room standing behind a glass partition. In a colourised cloud they look convincing, which is exactly the problem.
Water adds a second effect. Most scanners use near-infrared light, and water absorbs a lot of it, so the water surface itself often returns very few points. On a riverside scan you typically see a dark gap where the water is, with the ghost reflection sitting underneath it.
The surfaces that cause it
| Surface | What shows up in the cloud | What we do about it |
|---|---|---|
| Calm water (bays, ponds, reservoirs) | Few points on the surface, a mirrored ghost of the bank below it | Clip everything below the waterline during cleaning, and check the edge against photos |
| Glass curtain walls and partitions | Points behind the glass, reflections of the room you are standing in | Mark glazing on the site walk, add positions that see the frame head on, remove the phantom geometry |
| Polished floors and stone | A faint doubled ceiling or doubled furniture under the floor plane | Keep scan positions away from low grazing angles and delete points below the finished floor level |
| Stainless steel and chrome | Scattered noise and stretched shapes around the object | Extra positions and manual cleaning around plant and fittings |
How we handle it on a job
Most of the work happens before the scanner is switched on. On the site walk we note every large reflective surface, because it decides where the scan positions go. Positions that look across glass at a steep angle, rather than skimming along it, return far fewer false points.
After registration, the cloud is cleaned before anything is modelled from it. Ghost points are usually easy to separate once you know where the mirror is: everything below a waterline, or behind a glazing line, gets segmented and removed, then the result is checked against the site photographs. Skipping this step is how a phantom column ends up in a Revit model.
That cleaning is part of every 3D laser scanning job we deliver, and it matters most when the cloud goes on to become a model through Scan-to-BIM. If you have a waterfront site, an atrium or a glass-fronted building to document, tell us about it and we will say plainly what the reflective surfaces will need.
A note on the colours
The rainbow in the reflection is the same kind of colour ramp we use on our own point clouds and on our homepage. It maps height or distance to colour, so red and blue sit at the two ends of the range. It carries no meaning beyond making depth readable at a glance, which is also why we like it for a lantern festival.
From the Volumet team, we wish you and your family a bright and unhurried Mid-Autumn. 海上生明月,天涯共此时.